Semiconductor Equipment Model Manufacturer
Semiconductor Equipment Model Precision Manufacturing Case Study
Project Objectives
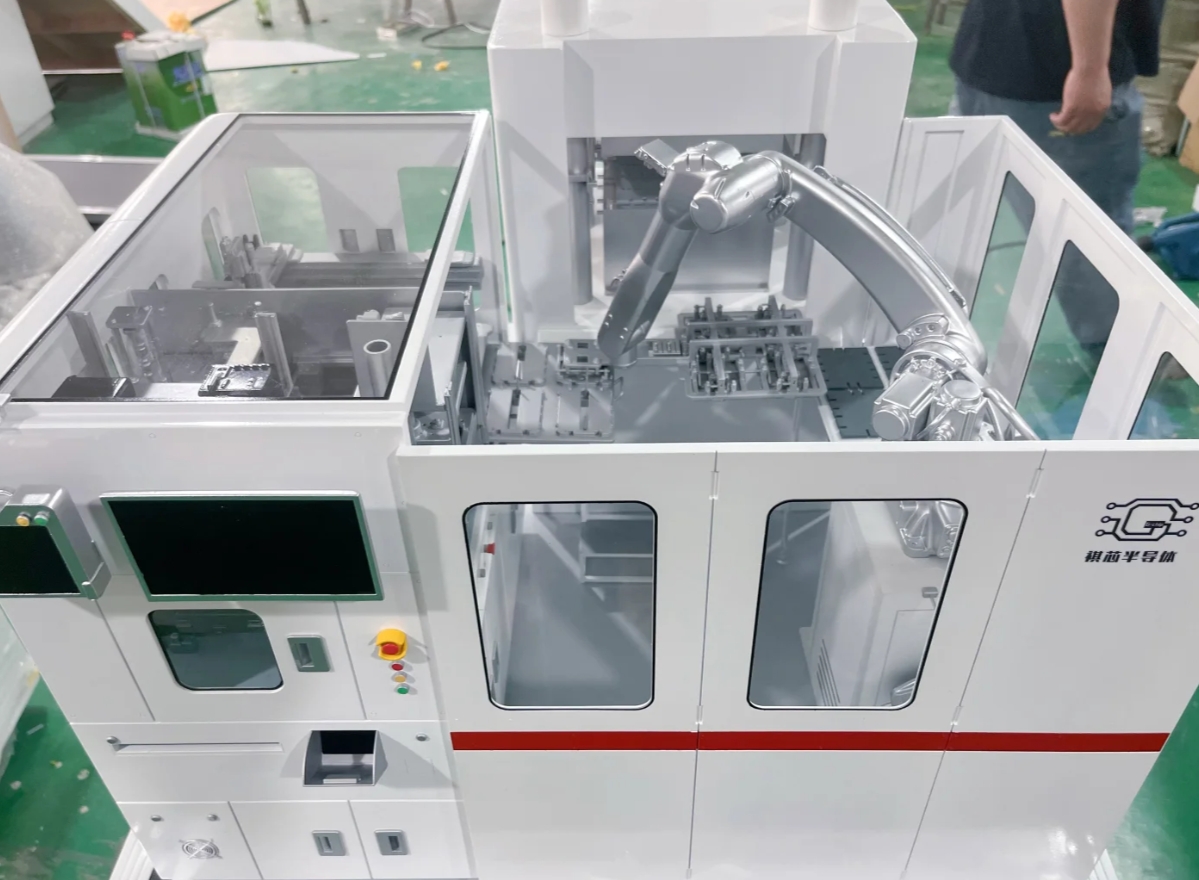
Customise a semiconductor process equipment model for a client, reproducing over 90% of the structural details of the actual equipment, with a focus on the robotic arm movement mechanism and modular cabin design.
1. Main Structure Manufacturing Process
Frame Construction
The main frame substrate is CNC-cut from high-density aerospace laminate panels, with laser-guided alignment and assembly for the load-bearing structure.
The cabin outer shell is vacuum-moulded from ABS engineering plastic, with critical curved surfaces reverse-engineered via 3D scanning to ensure arc joint gaps ≤0.1mm.
Precision Reconstruction of the Robotic Arm
Main joints: 316 stainless steel precision cast and CNC milled, with mirror-polished surfaces.
Movement mechanisms: 3D-printed nylon gear sets paired with miniature ball bearings to achieve a 270° real-world movement range.
End effectors: Aluminium alloy etching process to replicate real claw textures.
2. Industrial-Grade Detail Processing
Multi-colour coating system
Primer treatment: Sandblasted entire piece, then coated with epoxy primer to enhance adhesion
Main colour process:
Body: 5 layers of matte white automotive paint (including UV curing layer) to simulate industrial paint texture
Feature red line: Ferrari metallic red paint applied using masking spray technique, with sharp edges and no bleeding
Metal components: Electroplated matte silver layered coating, retaining the casting texture
Control panel simulation
Buttons: Silicone moulded, with LED micro-lights embedded at the bottom
Screen: High-transparency PMMA laser-engraved and screen-printed display interface
Emergency stop button: Independent metal knob with spring-loaded feedback
III. Dynamic system integration
Transparent cabin construction
Observation window uses anti-glare acrylic panels with internal etched equipment identification markings
Layered chamber structure: laser-cut 2mm transparent resin panels, argon arc welding method for assembly
Motion mechanism calibration
Robotic arm pre-installed with miniature servo motors, using magnetic coupling brushless transmission to reduce noise


